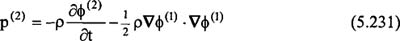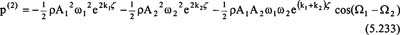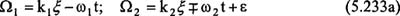The Dynamics Of Marine Craft: Maneuvering And Seakeeping

We have stated several times in this chapter that wave-induced forces and motions on ships in low to moderate sea states can be predicted reasonably well using linear theory provided that the roll damping is properly accounted for. However, for moored or anchored structures, second-order wave forces play an important role. These are proportional to the square of the wave amplitude, and in general involve two wave frequencies. These effects are particularly important for moored structures because they include a component that oscillates at a frequency corresponding to the difference between the two wave frequencies. This low frequency can coincide with the natural frequency of the moored structure in a horizontal plane, and thereby produce larger-amplitude oscillations than the wave-frequency forces.
It is instructive to examine the wave-induced pressure to second order in the absence of a body. In terms of the velocity potential, using the Bernoulli equation (Eq. (4.1)):
For monochromatic waves the solution is given in Eq. (4.69) for arbitrary water depth; in deep water this expression reduces to
However if there are two waves with frequencies ? 1 and ? 2, we obtain
in deep water, where ? is the total phase of each wave, e.g.:
and ? is a phase angle. Thus a new term appears, proportional to the difference between the wave frequencies (if the waves are travelling in the same direction), which would not be anticipated on the basis of the single-wave result.