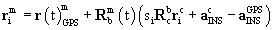Digital Terrain Modeling: Acquisition, Manipulation, and Applications

The formulation of the direct georeferencing mathematical model is rather straightforward. For details, see, for instance, Schwarz (2000). The standard implementation of this formula will, however, cause difficulties when low-accuracy gyros are used. The modifications necessary in this case will be discussed in this chapter. Figure 2.6 depicts airborne mobile mapping using a digital frame camera. The mathematical model is given in (2.11) for a camera system and will be used as the standard model in the following discussion. The terms in the equation are listed in Table 2.1.
| Variable | Obtained from |
|---|---|
| | The coordinate vector of point ( i) in the mapping frame (m-frame) (3 unknowns) |
| | The interpolated coordinate vector of GPS in the m-frame |
| S i | A scale factor, determined by stereo techniques, laser scanners, or from DTM |
| | The interpolated rotation matrix between the navigation sensor body frame (b-frame) and the m-frame |
| (t) | The time of exposure (i.e., the time of capturing the images), determined by synchronization |
| | The differential rotation (boresight) between the camera (c) frame and the INS body (b) frame, determined by calibration |
| | The coordinate vector of the point ( i) in the c-frame (i.e., image coordinate) |
| | The lever arm vector between INS center and camera principal point, determined by calibration |
| | The lever arm vector between INS center and GPS antenna center, determined by calibration |
| (2.11) | |
Implementation of this formula requires inertial and GPS measurements for the...