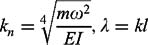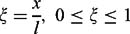Formulas for Structural Dynamics: Tables, Graphs and Solutions
This chapter is devoted to Bernoulli Euler uniform one-span beams with elastic (translational and torsional) supports. Fundamental characteristics, such as frequency equations, eigenvalues and eigenfunctions, are presented. For many cases, the frequency equation is presented in the different forms that occur in the various scientific examples. Special cases are discussed.
| A | Cross-sectional area | |
| A, B, C, E, S 1 | Hohenemser Prager functions | |
| E | Young's modulus | |
| EI | Bending stiffness | |
| I z | Moment inertia of a cross-section | |
| k n | Frequency parameter, | |
| k tr | Translational stiffness coefficients | |
| k rot | Rotational stiffness coefficients | |
| k * tr | Dimensionless translational stiffness coefficients, | |
| k * rot | Dimensionless rotational stiffness coefficients, | |
| l | Length of the beam | |
| m | Mass per unit length, m = ?A | |
| S, T, U, V | Krylov Duncan functions | |
| x | Spatial coordinate | |
| x, y, z | Cartesian coordinates | |
| X(x) | Mode shape | |
| ?, ? | Dimensionless auxiliary parameters | |
| ? | Frequency parameter, ? 4 EI = ml 4 ? 2 | |
| ? | Dimensionless coordinate, | |
| ? | Density of material | |
| ? | Natural frequency, |
Exact frequency equations and expressions for mode shape vibration for uniform beams with uniformly distributed masses and elastic supports at both ends are presented in Table 6.1. (Anan'ev, 1946; Gorman, 1975). These equations may be also presented in terms of Krylov Duncan and Hohenemser Prager functions. Frequency equations for special cases are presented in Table 6.2.