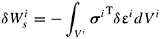Dynamics of Multibody Systems, Third Edition

5.3: GENERALIZED FORCES

5.3 GENERALIZED FORCES

In this section, we develop expressions for the generalized forces associated with the generalized coordinates of the deformable body i in the multibody system. We consider the elastic forces arising from the body deformation and also externally applied forces as well as restoring forces due to elastic and dissipating elements such as springs and dampers.

Generalized Elastic Forces

In this section, we consider a linear isotropic material. The more general case of nonlinear elastic, orthotropic materials can also be formulated by changing the form of the body stiffness matrix.

In the preceding chapter, it was shown that the virtual work due to the elastic forces can be written as

(5.97)

where ? i and ? i are, respectively, the stress and strain vectors, and ? is the virtual work of the elastic forces. Since the rigid body motion corresponds to the case of constant strains and since we defined the deformation with respect to the body reference, there is no loss of generality in writing the strain displacement relations in the following form:

(5.98)

where D i is a differential operator defined in the preceding chapter and is the deformation vector. In terms of the elastic generalized coordinates of body i, one may write Eq. 98 as

(5.99)

For a linear isotropic material, the constitutive equations relating the stress and strains can be written as

(5.100)

where E i is the symmetric matrix of elastic coefficients. Substituting Eq. 99...

UNLIMITED FREE
ACCESS
TO THE WORLD'S BEST IDEAS

SUBMIT
Already a GlobalSpec user? Log in.

This is embarrasing...

An error occurred while processing the form. Please try again in a few minutes.

Customize Your GlobalSpec Experience

Category: Mechanical Testing Services
Finish!
Privacy Policy

This is embarrasing...

An error occurred while processing the form. Please try again in a few minutes.