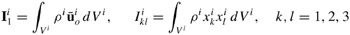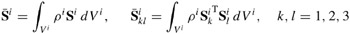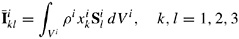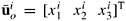Dynamics of Multibody Systems, Third Edition

In the floating frame of reference formulation described in this chapter, the configuration of each deformable body in the multibody system is identified by using two coupled sets of generalized coordinates: reference and elastic coordinates. Reference coordinates define the location and orientation of the deformable body reference, while elastic coordinates define the deformation of the body with respect to the body coordinate system. The use of the mixed set of reference and elastic coordinates in the floating frame of reference formulation leads to a highly nonlinear mass matrix as a result of the inertia coupling between the reference and the elastic displacements.
It is shown in this chapter that even though the mass matrix is highly nonlinear, the deformable body inertia can be defined in terms of a set of inertia shape integrals that depend on the assumed displacement field. These shape integrals are
| (5.142) | |
| (5.143) | |
| (5.144) | |
where
is the undeformed position of an arbitrary point on the deformable body i in the multibody system; ? i and V i are, respectively, the mass density and volume of body i; and
is the kth row in the body shape function S i. In the special case of rigid body analysis the shape integrals are given by Eq. 142 only; these are the same shape integrals defined in Chapter 3. On the other hand, in the case of structural systems, wherein the reference...