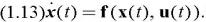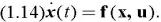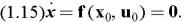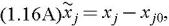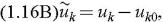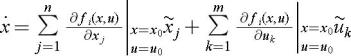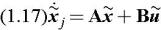1.7 LINEARIZATION OF THE STATE EQUATION OF A GENERAL TIME-INVARIANT CONTROL SYSTEM
The state equation of a general time-invariant system is given by
For simplicity, we are just writing Equation (1.13) as
Let ( x 0, u 0) be an equilibrium point. This means the system is in equilibrium under the conditions x 0 and u 0, i.e.,
Equation (1.15) shows that the derivatives of all the state-variables are zero at the equilibrium point. Thus, the system continues to lie at the equilibrium point unless otherwise disturbed.
The state-Equation (1.14) of a general time-invariant system can be linearized about the equilibrium point ( x 0, u 0) by expanding it into Taylor's series and neglecting second-and higher-order terms.
Thus, the i th state equation is given by
Define the variations about the equilibrium point ( x 0, u 0) as
Also, from (1.16 A) we have
Now, for f i ( x 0, u 0) = 0; the linearized i th state-equation is given by
When writing the above linearized state equations in vector-matrix form
The matrices A and B are called the Jacobian Matrices and all the partial derivatives in matrices A and B are evaluated at the equilibrium point ( x 0, u 0).

 TABLE OF CONTENTS