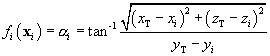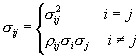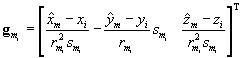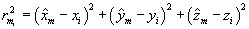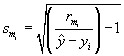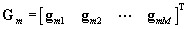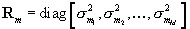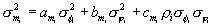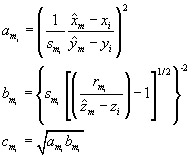Electronic Warfare Target Location Methods
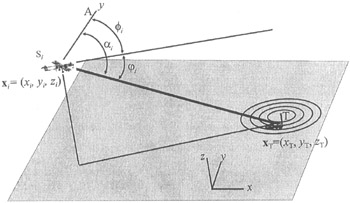
A different approach to iterating toward a PF solution was presented by Paradowski [18]. Given the ith azimuth AOA ? i and the ith elevation AOA ? i, the generalized bearing ? i is determined as indicated in Figure 2.29. The generalized bearing is in the plane defined by triangle TS iA and is given by
| (2.227) | |
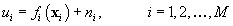
The measurements are expressed as
| (2.228) | |
or
| (2.229) | |
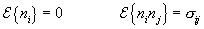
where, in the absence of measurement errors u i = f i( x i) = ? i, and f i( x i) is the function in which the PF and LOB information is contained. The measurement noise, n i, is characterized by
| (2.230) | |
| (2.231) | |
? i and ? j are standard deviations for the ith and jth measurements and ? ij is the correlation coefficient between these measurements.
The gradient vector at the mth step in the iteration toward the solution is given by
| (2.232) | |
where
| (2.233) | |
and
| (2.234) | |
The gradient matrix consists of rows that are the gradient vectors
| (2.235) | |
At the mth iteration, the covariance matrix of generalized bearing errors is a diagonal matrix expressed as
| (2.236) | |
where
is the variance of the ? i error at the mth iteration. These can be expressed in terms of the variances of the measurements as
| (2.237) | |
where
Given that the...